
How Human Demonstrations Bridge the Gap Between AI Models and Physical Robots
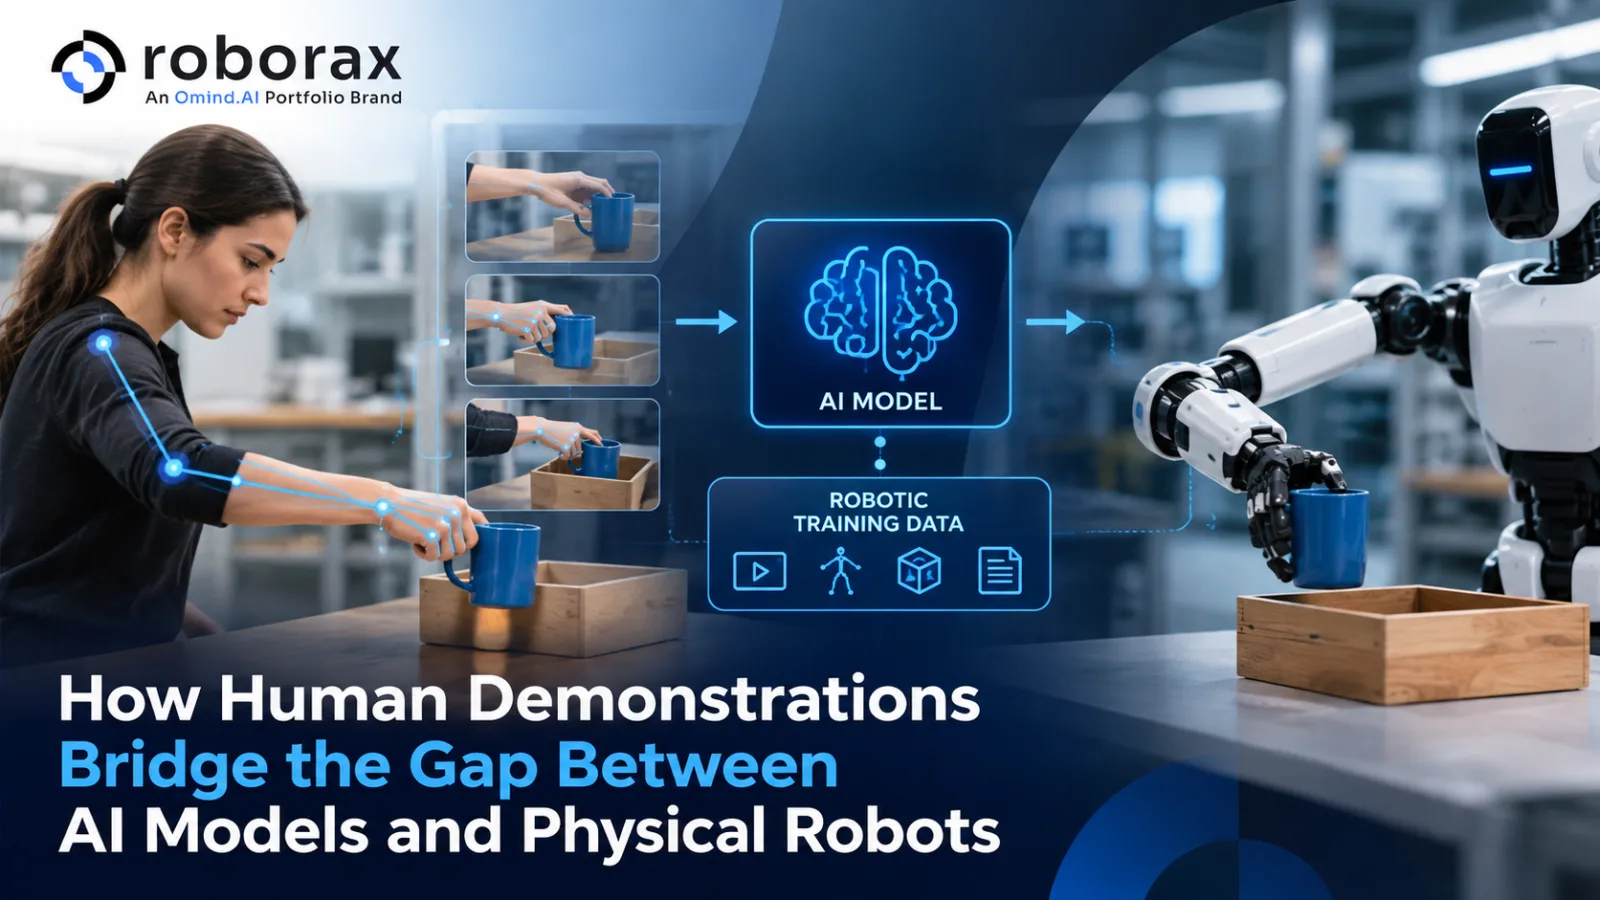
Artificial Intelligence Has Become Remarkably Capable at Understanding Images, Language, Patterns, and Complex Instructions. Yet Transferring These Capabilities Into the Physical World Remains a Major Challenge. A Robot May Understand What It Means to “Pick up a Cup,” but Understanding the Instruction Is Very Different From Reliably Performing the Task in a Changing Physical Environment.
This Is Where Human Demonstrations Become Valuable. By Observing or Recording People Performing Real-World Tasks, Robotics Teams Can Create Practical Examples of How Intentions Translate Into Physical Actions. Human Demonstration Data for Robot Learning Provides a Bridge Between Abstract AI Capabilities and the Sensorimotor Skills Required by Physical Machines.
For companies developing embodied AI and next-generation robots, this connection is becoming increasingly important.
Why AI Models Struggle With the Physical World
Modern AI models can process enormous amounts of digital information. However, robots operate under constraints that conventional AI models do not encounter in the same way.
A physical robot must account for factors such as object position, friction, weight, lighting, obstacles, grasp stability, camera perspective, and unexpected changes in the environment. Even a simple action such as placing an object on a shelf involves perception, planning, movement, force control, and timing.
This creates an embodiment gap between what an AI model knows conceptually and what a robot must physically execute.
Robot learning addresses this problem by exposing models to examples of actions and outcomes. However, collecting demonstrations directly with robots can be expensive and time-consuming. Research has highlighted the difficulty of scaling physical robot demonstrations because every example requires interaction with hardware and the real environment.
Human demonstrations offer another path.
Human Actions Provide a Blueprint for Robot Skills
Humans naturally perform everyday activities while adapting to objects, environments, and unexpected situations. A person picking up a bottle does not simply follow a fixed trajectory. They adjust their hand position, grip, speed, and movement based on the bottle's location and characteristics.
Capturing these behaviors gives AI systems useful information about how tasks are accomplished, rather than only describing what the desired outcome should be.
For example, a human demonstration of a pick-and-place task can capture:
The initial position of the object
Hand and arm movement
Object interaction
Grasp timing
Movement trajectory
Release behavior
Environmental context
Variations in how the task is performed
When properly collected and processed, these observations can become valuable robotic training data for imitation learning, policy development, and embodied AI systems.
From Demonstration to Robotic Training Data
A human demonstration alone is not automatically useful to a robot. The information must be structured into a format that learning systems can interpret.
Depending on the application, data collection may involve RGB or RGB-D cameras, motion tracking, wearable sensors, instrumented objects, teleoperation interfaces, or other sensing technologies. The resulting recordings can then be processed to identify actions, object interactions, poses, trajectories, and task stages.
For example, a demonstration involving a person moving an object from one location to another could be transformed into a sequence such as:
Observe → Reach → Grasp → Lift → Move → Place → Release
Each stage can provide training signals for a robotic policy.
This process transforms natural human behavior into structured data that can support learning algorithms.
Closing the Embodiment Gap
One of the biggest challenges in using human demonstrations is that humans and robots have different physical embodiments. Human arms, hands, joints, and movement capabilities are not identical to those of robotic systems.
Consequently, a robot cannot always reproduce a human movement literally.
Instead, AI systems must learn the underlying intent and task structure. A human demonstration can show that an object needs to be grasped from a particular location, moved around an obstacle, and placed at a destination. The robot can then determine how to achieve the same objective using its own morphology and available degrees of freedom.
Recent research specifically identifies embodiment differences as a central challenge when transferring human demonstrations to robots. At the same time, appropriately labeled human demonstrations can provide substantial value when combined with robot-collected data.
This makes demonstration data particularly useful as a complementary source of training information.
Human Demonstrations Can Improve Data Diversity
Robots can perform the same task repeatedly, but collecting every possible variation through physical robot execution can require substantial resources.
Human demonstrations can introduce diversity more efficiently.
Different people may approach the same task using different trajectories, speeds, grips, and strategies. Demonstrations can also be captured across different environments, object configurations, and task conditions.
This diversity can help models learn the broader structure of a task rather than memorizing a single motion sequence.
Research into demonstration-based learning has also shown that the modality used to collect demonstrations affects both user experience and downstream learning performance. Combining different collection approaches can offer a practical balance between data quality and scalability.
Connecting Foundation Models With Physical Actions
Foundation models provide powerful capabilities for perception, reasoning, language understanding, and generalization. But physical robots require an additional layer: grounded action.
Human demonstrations can provide that grounding.
An AI model may interpret a command such as “organize the objects on the table.” Demonstration data can help connect this high-level instruction to physical behaviors such as identifying objects, reaching toward them, grasping them safely, determining placement locations, and adapting to changes in the scene.
This creates a learning pipeline in which:
Language and perception → Task understanding → Human demonstration → Action representation → Robot policy → Physical execution
The demonstration effectively connects abstract model representations with real-world behavior.
Building Better Datasets for Physical AI
The value of Human Demonstration Data for Robot Learning ultimately depends on the quality of the dataset.
High-quality collection should capture more than successful movements. It should represent meaningful task variations, environmental context, object interactions, and, where possible, unsuccessful attempts and corrections.
Important dataset considerations include:
Consistent sensor synchronization
Accurate pose and action information
Diverse task environments
Multiple object configurations
Clear task boundaries
High-quality demonstrations
Appropriate metadata and labeling
Data validation and quality control
Well-designed datasets can then support imitation learning, supervised policy learning, simulation-based training, and hybrid approaches that combine human and robot demonstrations.
From Human Experience to Machine Capability
The long-term potential of human demonstrations goes beyond teaching robots individual movements. The objective is to capture the principles behind human interaction with the physical world and make those principles useful to intelligent machines.
Emerging approaches are already exploring ways to extract information from human demonstrations and use it to generate additional training experiences in simulation, helping overcome the limited scale of physical robot data.
This points toward a future in which human demonstrations become one component of a much larger data engine for physical AI.
Conclusion
The gap between AI models and physical robots is not simply a hardware problem. It is fundamentally a data and learning problem. AI systems need examples that connect perception and reasoning with physical actions, environmental changes, and task outcomes.
Human demonstrations provide that connection.
By converting real-world human behavior into structured robotic training data, robotics teams can give models practical examples of how tasks are performed. When combined with simulation, robot-generated data, teleoperation, and advanced learning methods, human demonstrations can help create more capable, adaptable, and general-purpose robotic systems.
For the next generation of embodied AI, learning from how humans interact with the physical world may be one of the most effective ways to turn powerful AI models into robots that can actually act.
0 comments
Log in to leave a comment.
Be the first to comment.