
Building Perception-Action Datasets for More Intelligent Autonomous Robots
Explore how perception-action datasets, robotic training data, and multimodal sensor capture improve autonomous robot intelligence and Physical AI.
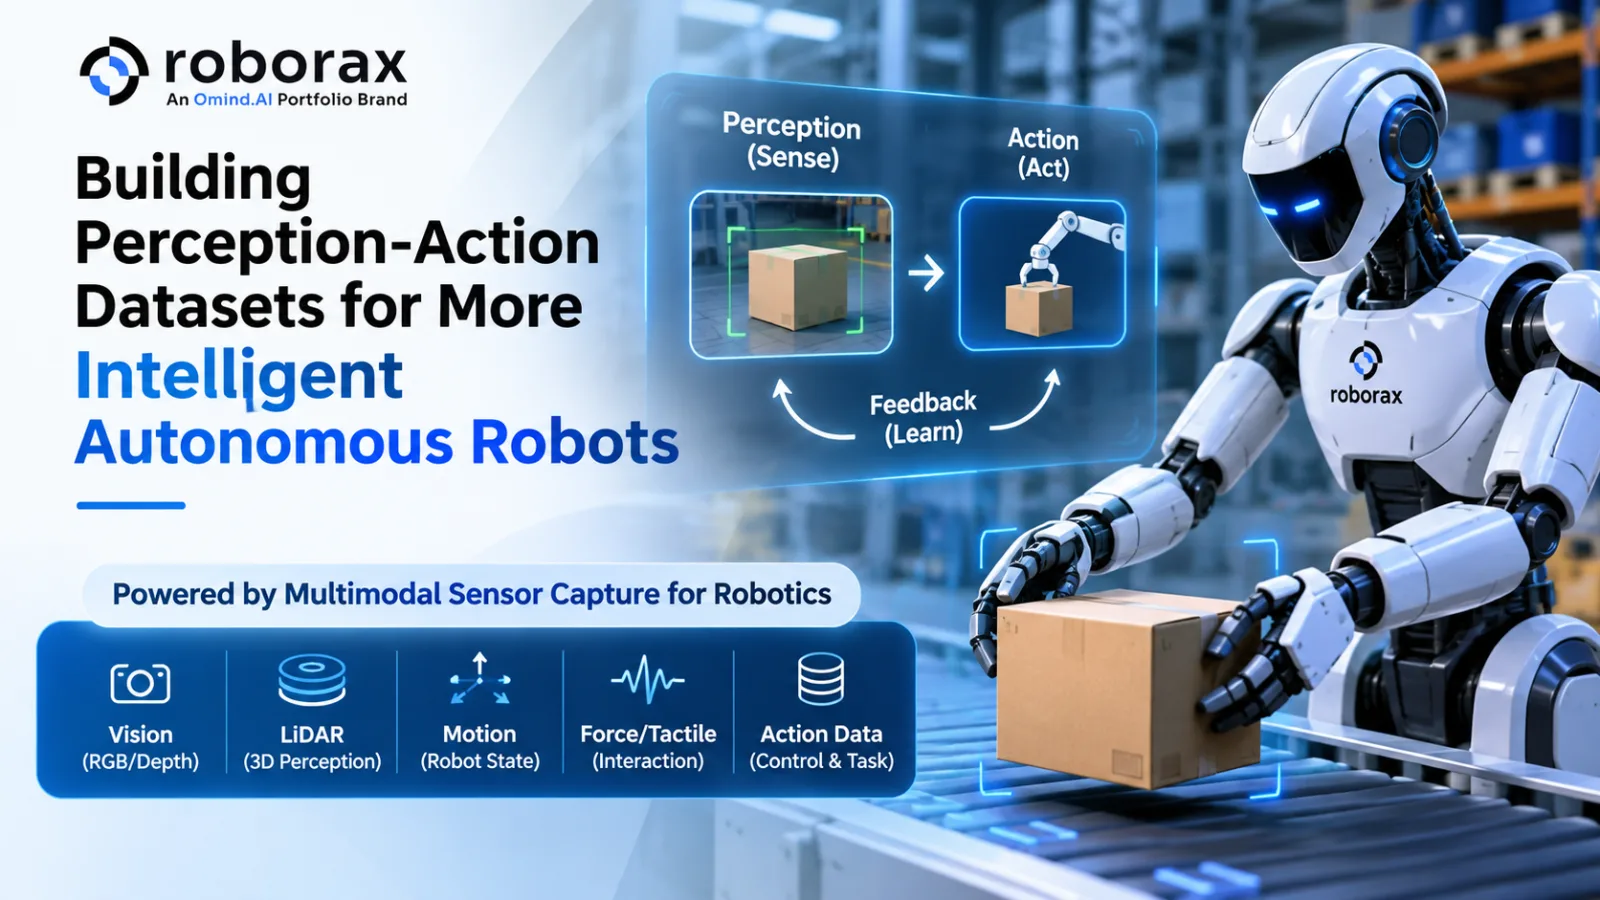
Autonomous Robots Are Becoming Increasingly Capable of Performing Complex Tasks in Dynamic, Unpredictable Environments. From Warehouse Automation and Industrial Manufacturing to Autonomous Navigation and Mobile Manipulation, Modern Robotic Systems Must Do More Than Recognize Objects or Interpret Visual Information. They Need to Understand Their Surroundings, Make Informed Decisions, and Execute Physical Actions While Continuously Responding to Environmental Changes. Achieving This Level of Intelligence Requires High-Quality Perception-Action Datasets That Connect What Robots Observe With How They Behave.
Traditional robotics datasets have largely focused on individual sensor modalities, such as camera images, LiDAR scans, or motion trajectories. However, these isolated data sources provide an incomplete representation of real-world interactions. Developing intelligent autonomous systems requires synchronized information about environmental conditions, robot movements, contact events, and task outcomes. This is where comprehensive robotic training data becomes essential for advancing Physical AI and embodied intelligence.
Understanding Perception-Action Datasets in Robotics
Perception-action datasets capture the relationship between a robot's sensory observations, decision-making processes, and physical actions. Rather than treating perception and control as separate stages, these datasets connect them within a continuous learning framework.
For example, when a robotic arm picks up an object, its cameras identify the object's position and orientation, while depth sensors estimate its distance. Joint encoders record arm movements, and force-torque sensors detect physical contact. The robot's gripper then adjusts its force based on feedback to complete the grasp successfully.
A well-structured perception-action dataset records these interconnected events, allowing machine learning models to understand how environmental observations influence physical behavior.
Such datasets typically include:
Visual observations: RGB images, depth maps, and video streams capturing objects and surroundings.
Spatial information: LiDAR point clouds, 3D coordinates, and environmental geometry.
Robot state information: Joint positions, velocities, accelerations, and end-effector poses.
Action trajectories: Movement commands, navigation paths, manipulation sequences, and control signals.
Interaction feedback: Force, torque, tactile responses, and contact information.
Task outcomes: Successful executions, failed attempts, collision events, and recovery behaviors.
Combining these data types provides a more complete understanding of how autonomous robots perceive and interact with their environments.
Why Autonomous Robots Need Connected Perception and Action Data
Robotic intelligence depends on the ability to translate sensory information into appropriate physical responses. A robot may accurately identify an object but still fail to grasp it if its training data does not adequately connect object recognition with manipulation strategies.
Perception-action datasets address this limitation by helping models learn the relationship between environmental conditions and appropriate actions.
1. Improving Real-Time Decision-Making
Autonomous robots frequently encounter changing environments. Objects may move, obstacles may appear, and operating conditions may differ from those observed during training.
Training models on perception-action sequences helps robots associate changing sensory inputs with appropriate behavioral responses. This supports more adaptive decision-making in real-world applications.
2. Developing More Reliable Manipulation Skills
Robotic manipulation requires precise coordination between visual perception, motion planning, and physical feedback. Datasets containing synchronized visual, positional, and tactile information help models understand how to approach, grasp, move, and release objects.
This is particularly important for warehouse picking, assembly operations, and mobile manipulation.
3. Supporting Learning from Experience
Robots must learn from both successful and unsuccessful interactions. Recording failed grasps, unexpected collisions, incorrect movements, and recovery attempts creates valuable examples for improving future performance.
These examples help machine learning systems develop more robust behavioral policies.
The Role of Multimodal Sensor Capture for Robotics
Building effective perception-action datasets requires collecting information from multiple sensors operating simultaneously. Multimodal Sensor Capture for Robotics enables developers to combine visual, spatial, motion, and interaction data into synchronized training resources.
Each sensor contributes a different perspective on the robot's operating environment.
For instance, RGB cameras capture object appearance, while depth cameras provide distance measurements. LiDAR sensors generate detailed spatial representations, and inertial measurement units (IMUs) capture acceleration and rotational movement. Force-torque sensors and tactile systems provide information about physical interactions.
However, collecting these modalities independently is not sufficient. Accurate synchronization is necessary to establish meaningful relationships between sensory observations and corresponding robot actions.
Robotics data pipelines should therefore incorporate:
Timestamp synchronization across different sensor streams.
Calibration of camera, LiDAR, and robot coordinate systems.
Consistent recording of robot states and control commands.
Alignment of visual observations with action trajectories.
Validation of missing, duplicated, or inconsistent sensor records.
These processes ensure that the resulting datasets accurately represent the sequence of events occurring during robotic operations.
Essential Steps in Building High-Quality Perception-Action Datasets
Creating reliable datasets requires a structured approach that covers data acquisition, annotation, validation, and quality assurance.
1. Define Task-Specific Data Requirements
Dataset development should begin with clearly defined robotic tasks. Navigation, object manipulation, autonomous inspection, and warehouse picking require different combinations of sensory observations and action labels.
Defining these requirements helps determine which sensors, recording frequencies, and annotation categories are necessary.
2. Capture Real-World Robot Interactions
Robots should be exposed to diverse operating conditions, including different object positions, lighting environments, surface textures, obstacle configurations, and interaction scenarios.
Teleoperation and human demonstrations can also provide valuable examples of task execution, particularly for complex manipulation activities.
3. Synchronize Multimodal Data Streams
Sensor observations must be aligned with robot states and corresponding actions. Even small synchronization errors can create misleading relationships between perception inputs and physical responses.
Accurate timestamps, calibration procedures, and synchronization checks are essential for maintaining temporal consistency.
4. Annotate Actions and Environmental Events
Annotation transforms raw sensor recordings into structured learning resources. Labels may include object interactions, grasping phases, movement intentions, contact events, collision detection, task completion, and recovery actions.
Consistent annotation guidelines help ensure that similar events receive uniform labels across different recording sessions.
5. Implement Dataset Quality Assurance
Quality validation should examine sensor completeness, annotation accuracy, temporal alignment, trajectory consistency, and coverage of different operating conditions.
Human review and automated validation procedures can identify incorrect labels, missing observations, and inconsistent action sequences before model training begins.
Overcoming Challenges in Perception-Action Dataset Development
Despite their importance, perception-action datasets present several technical challenges.
One major issue is the complexity of synchronizing high-frequency sensor streams. Camera frames, LiDAR scans, joint states, and tactile measurements may operate at different sampling rates, making temporal alignment difficult.
Another challenge is dataset diversity. Models trained on limited environments may struggle when exposed to unfamiliar objects, unusual lighting, unexpected obstacles, or different physical conditions.
Annotation complexity also increases as datasets incorporate more sensor modalities and longer action sequences. Maintaining consistent labels across these interconnected data sources requires specialized workflows and domain expertise.
Robotics teams must also consider data scalability, storage requirements, privacy, and dataset versioning to ensure that training resources remain reliable as projects evolve.
Addressing these challenges requires combining robust data engineering, specialized annotation processes, and continuous quality monitoring.
How Roborax Supports Better Robotic Training Data
At Roborax, we recognize that intelligent autonomous robots require more than isolated sensor recordings. They need structured, synchronized, and task-relevant datasets that connect environmental perception with physical actions.
Our robotics data capabilities support the development of high-quality robotic training data through multimodal sensor capture, data annotation, human demonstrations, teleoperation, and dataset preparation workflows.
By organizing information from cameras, LiDAR, motion sensors, and robot interaction systems, Roborax helps robotics teams build datasets that support perception, manipulation, navigation, and embodied learning applications.
Our focus on Multimodal Sensor Capture for Robotics also helps address the need for synchronized sensory observations and action-related information across complex robotic workflows.
Conclusion
Building perception-action datasets is a fundamental step toward developing more intelligent and adaptable autonomous robots. By connecting sensory observations, environmental feedback, robot movements, and task outcomes, these datasets provide machine learning models with a richer understanding of real-world interactions.
As Physical AI continues to evolve, robotics teams will increasingly depend on diverse, synchronized, and accurately annotated datasets to improve model reliability and generalization. Investing in structured data acquisition, multimodal synchronization, and annotation quality will be essential for transforming autonomous robots from systems that simply recognize their surroundings into intelligent machines capable of interacting with the physical world.
Roborax supports this evolution by helping robotics teams develop the high-quality data foundations needed to advance next-generation autonomous systems.
0 comments
Log in to leave a comment.
Be the first to comment.